Libraries
Explore our open-source Modelica libraries through worked examples.
 Roll2RollDynamics
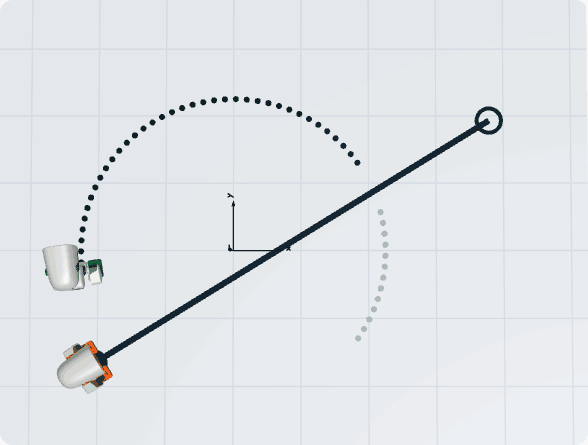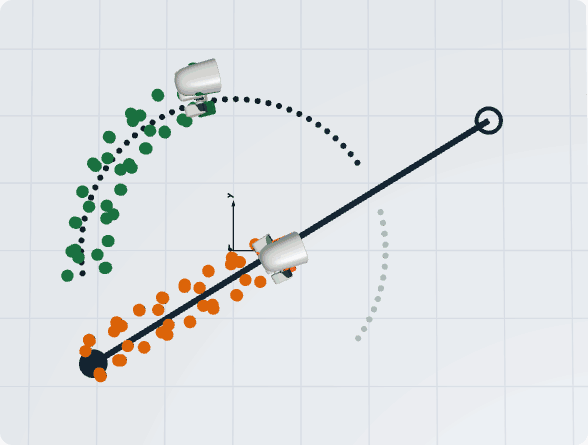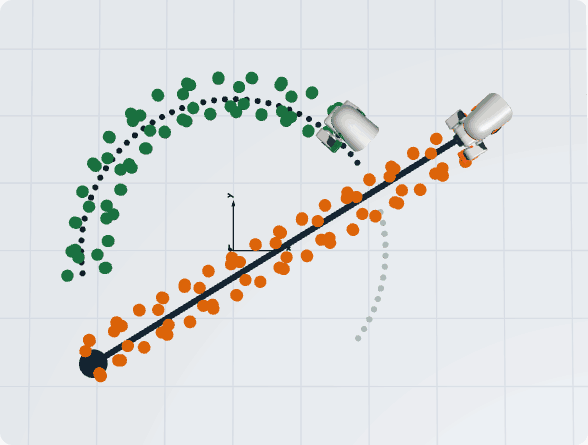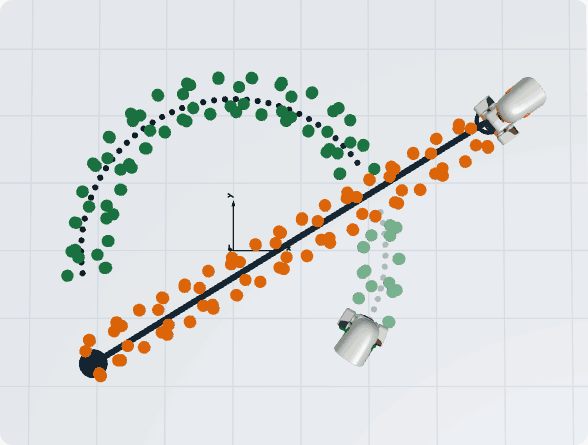
Follow a moving web through winding, roller contact and changes in its path.
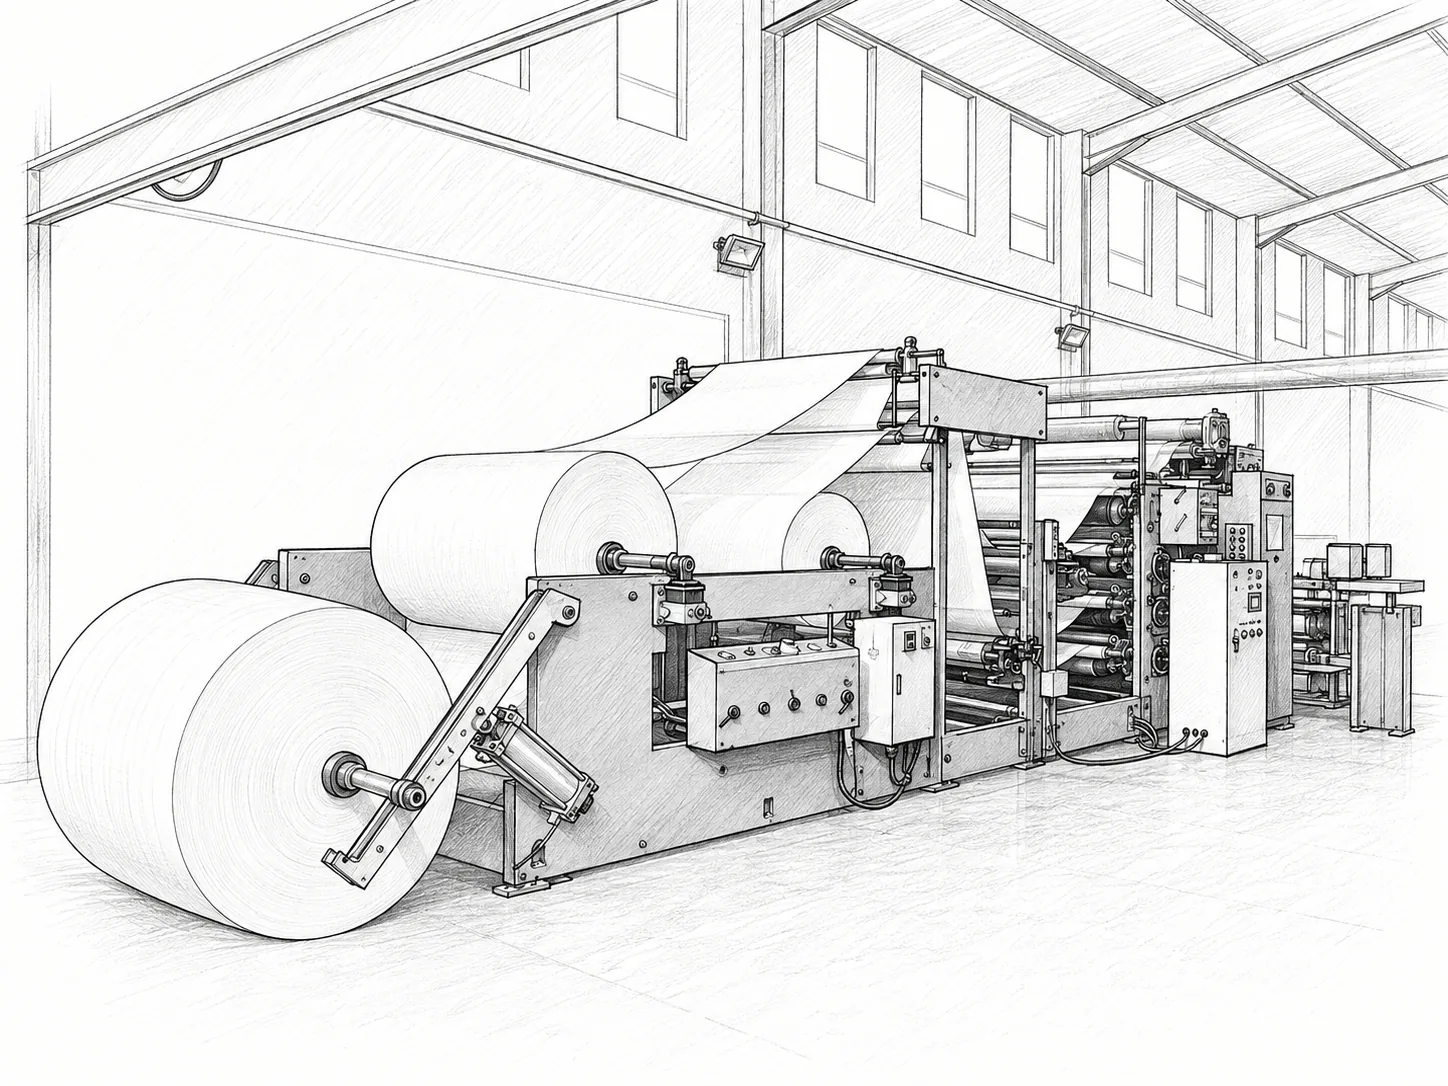
Misaligned idler
Explore how a small roller misalignment changes web tracking while span tension remains nearly unchanged.
Explore example →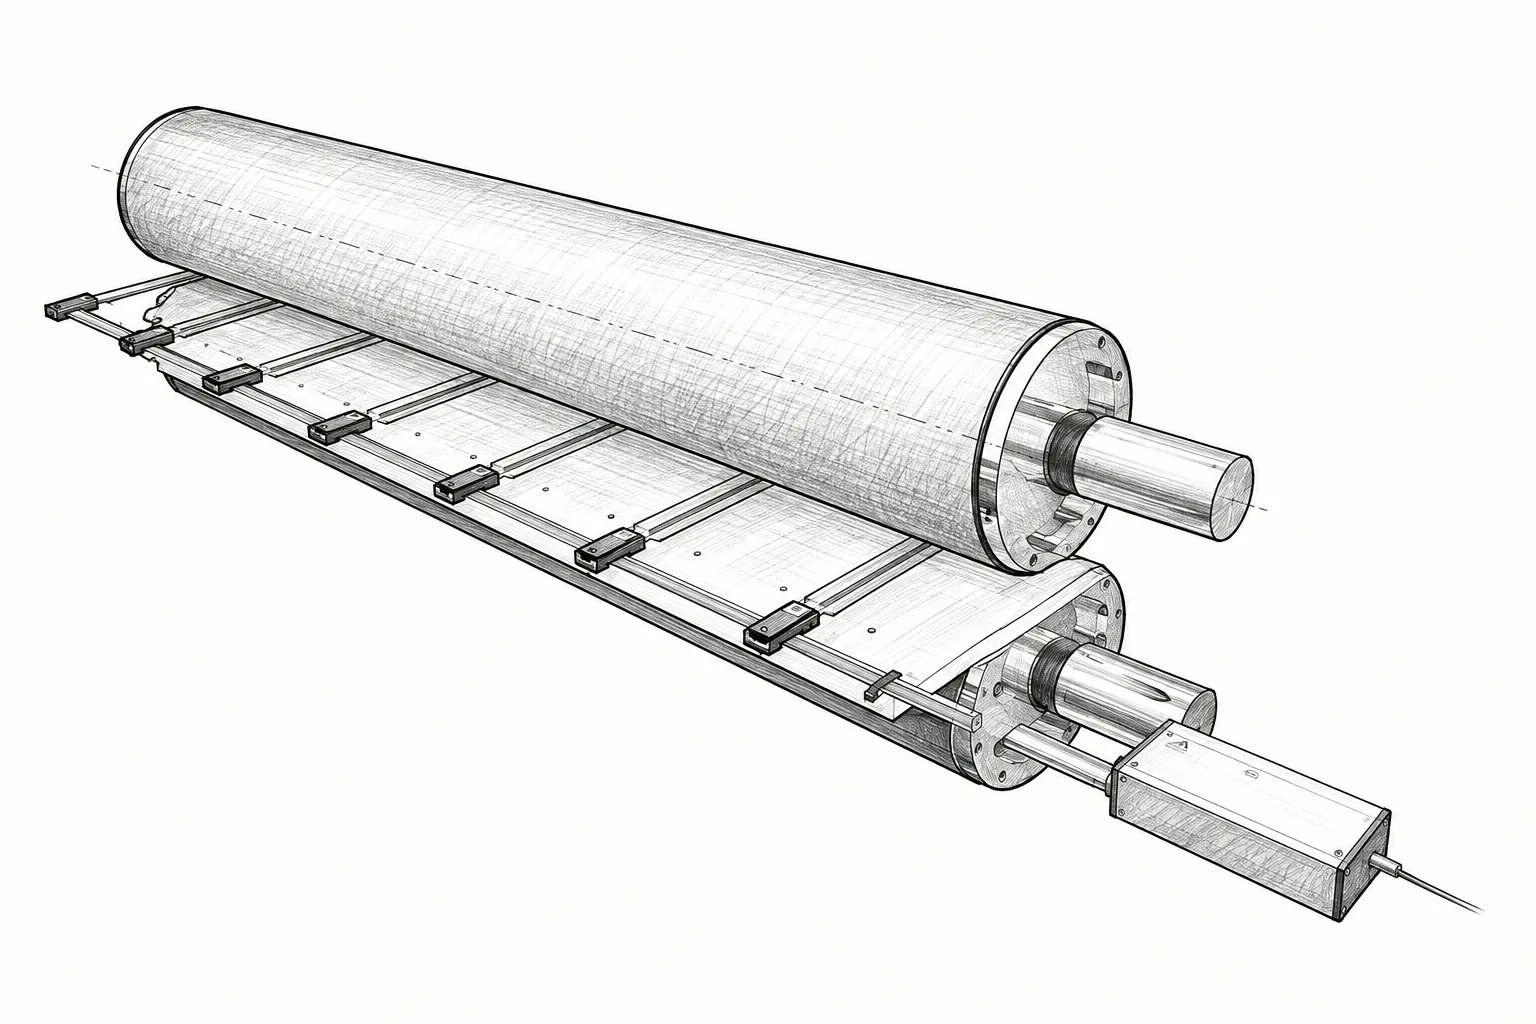
Nip loading
Follow nip engagement and release to connect contact load with traction and roller spin-up.
Explore example →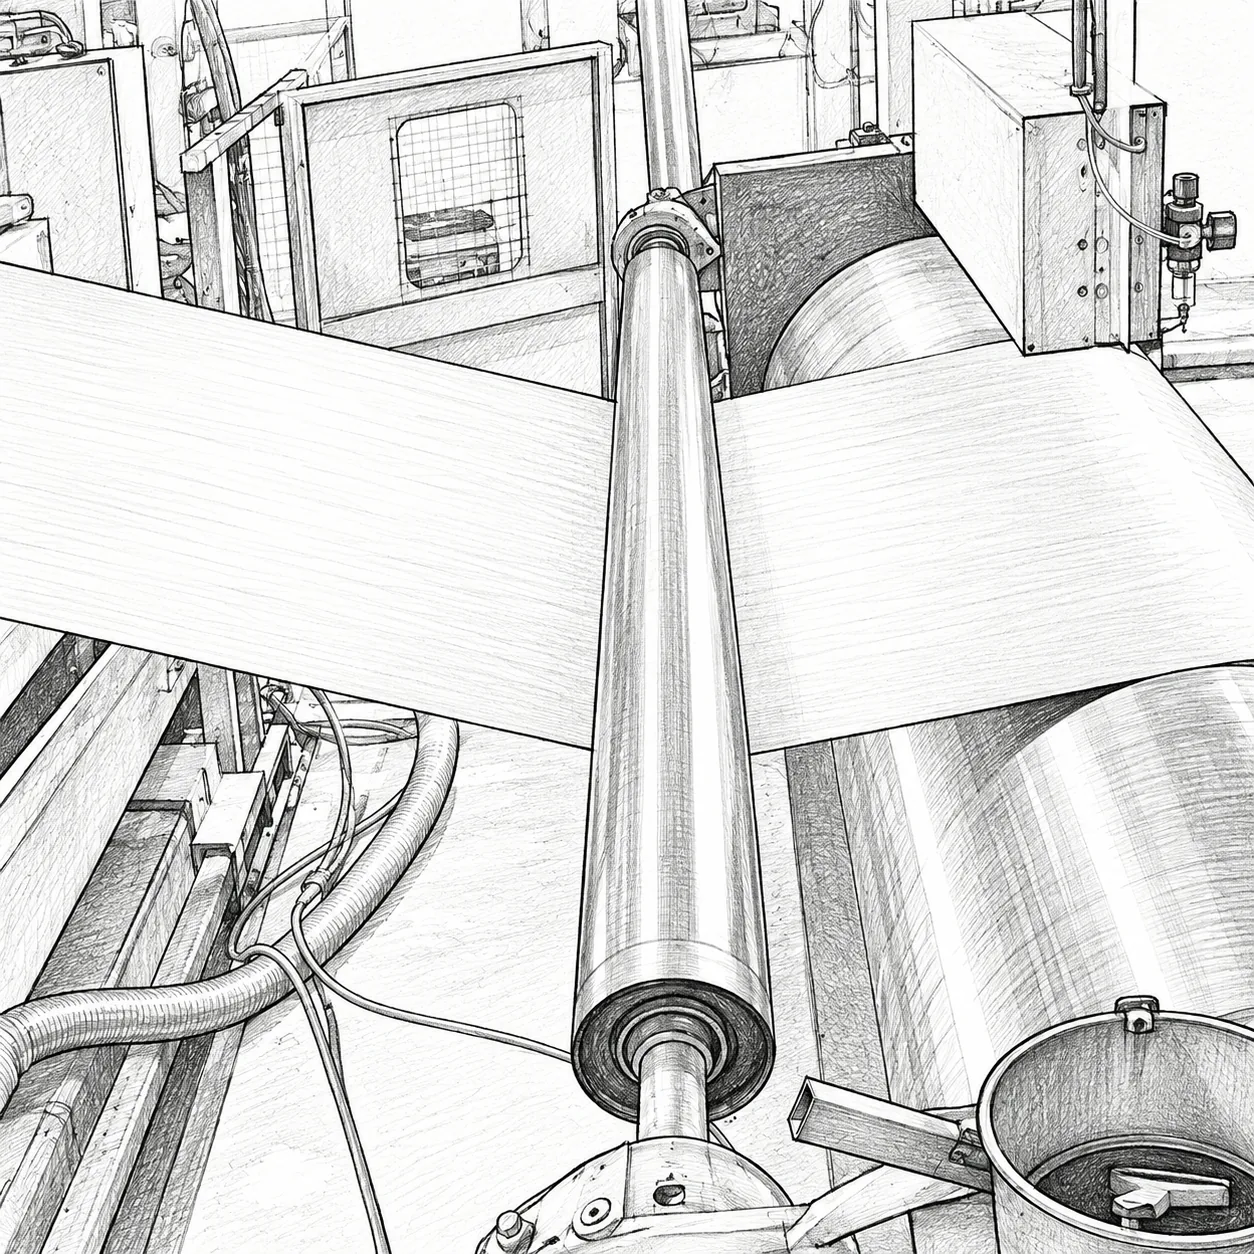
Retracting idler
Follow wrap, clearance, idler speed and span tension as a roller leaves a moving web and returns to it.
Explore example →RoboticsAtelier
Plant models of legged robots and manipulators: actuators, contact and power written as physics, verified against the simulator the robot was trained in.
 MicroDuck
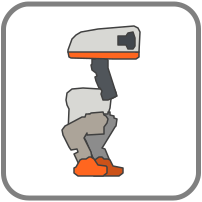
A 25 cm biped with 14 servos, walking under the neural network policy Pollen Robotics trained in MuJoCo.
Explore robot →Working with a similar system?
Tell us what you need to understand, predict or control.
Talk to an Expert